Project Overview
The RoboCup Middle-Size League (MSL) is one of the most demanding competitive testbeds in autonomous mobile robotics. Fully autonomous multi-agent teams of wheeled robots compete at high speeds on an indoor field, executing coordinated dynamic strategies without human intervention.
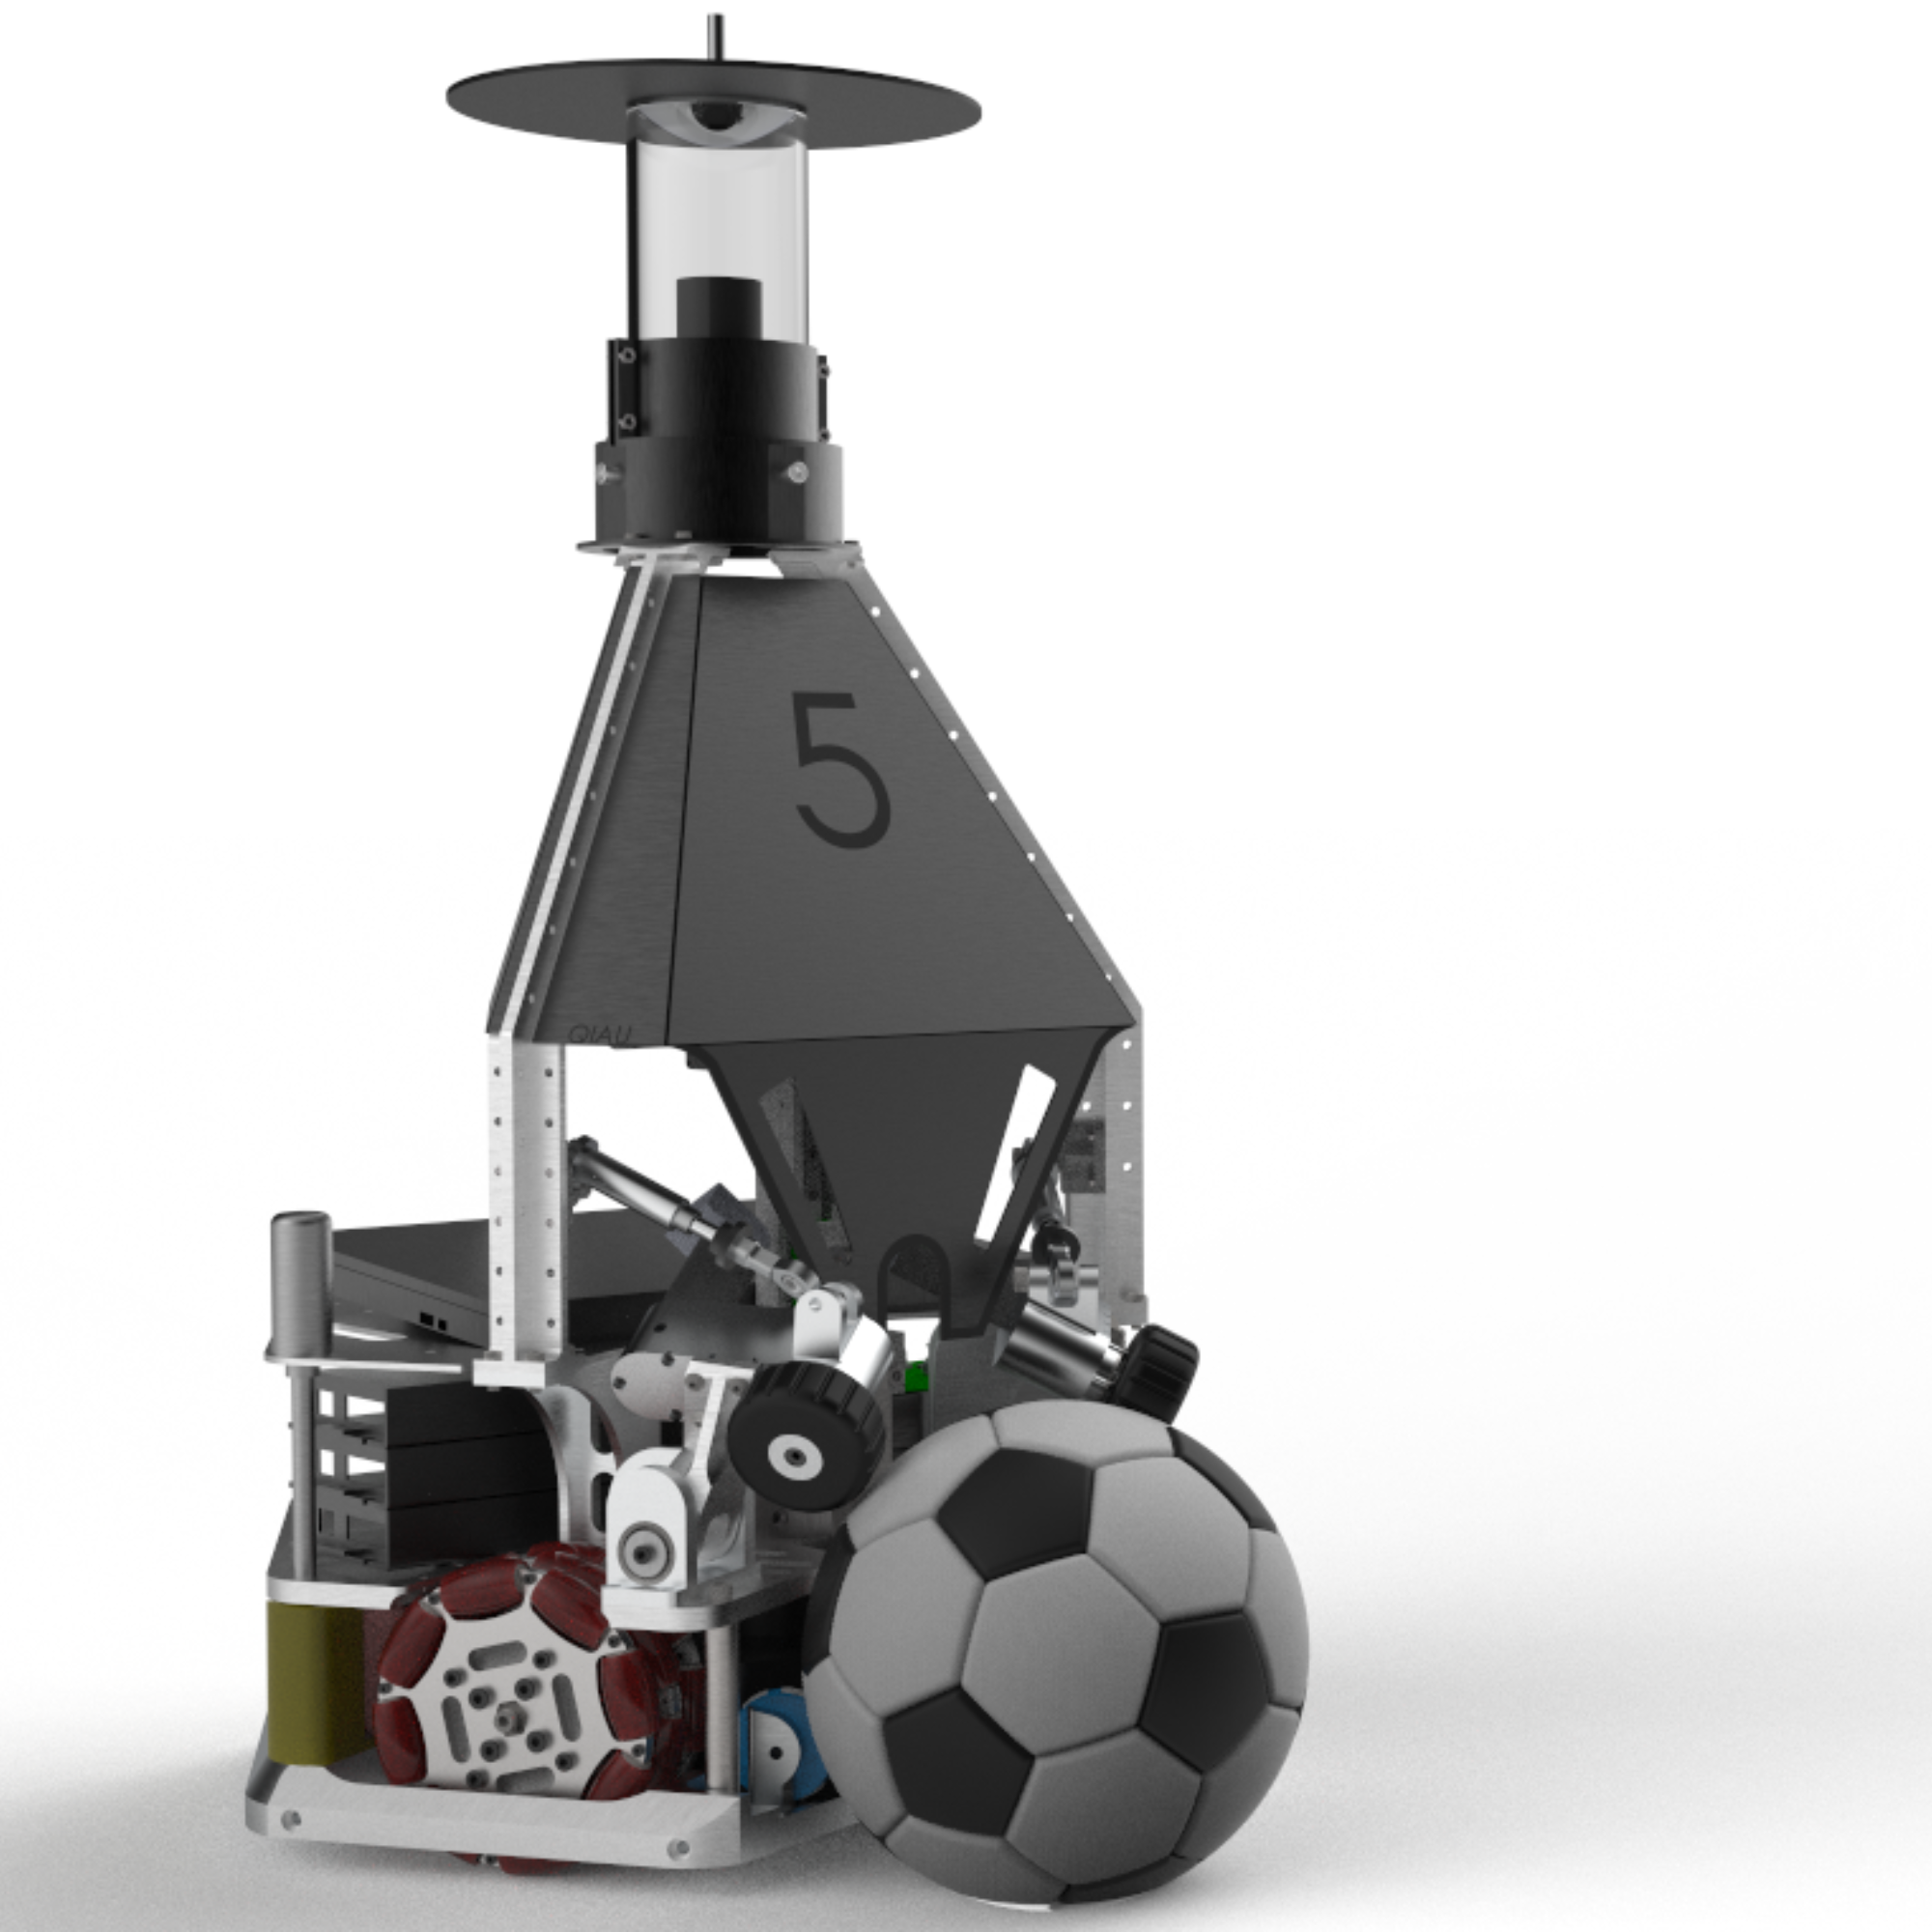
Qazvin Azad University engaged Cadrill to deliver the entire mechanical design and spatial packaging of the robot platform in SolidWorks. The scope encompassed structural chassis design, high-torque drivetrain gearboxes, omni-directional wheel assemblies, electronic hardware mounting plates, a dynamic ball-handling mechanism and a high-energy solenoid-based kicking device.
The Engineering Challenge
In competitive autonomous robotics, mechanical packaging constraints are severe. The platform must house massive drive motors, custom reduction gearboxes, high-voltage kicker capacitors, multiple electronic controller boards and vision camera towers within an exact height and footprint boundary defined by international RoboCup regulations.
The chassis had to resist direct high-speed collisions, maintain a low centre of gravity to prevent roll-over during sudden directional reversals, and provide rapid modular access for field technicians replacing batteries and servicing electronics between competition matches.
Cadrill's Design Approach
Using SolidWorks, Cadrill created a top-down master CAD model ensuring exact mechanical and geometric coordination across all sub-systems:
Chassis & Structural Architecture: Multi-tiered CNC-machined aluminium decks were designed with weight-saving pockets, rigid vertical standoffs and perimeter collision bumper mounts, achieving exceptional torsional stiffness at minimum overall mass.
Custom Gearboxes & Omni-Drive: Bespoke spur-gear transmission housings were engineered directly into the wheel mounting brackets, positioning powerful DC motors low within the chassis while providing precision bearing supports for internal gears and output drive axles.
Solenoid Kicker & Ball Handling: An electromagnetic plunger mechanism was integrated along the central forward axis, guided by linear bearings to shoot the ball with repeatable force. Above the kicker, dual motorized active dribbler rollers were designed to manipulate and trap the ball during forward acceleration.
Electronics & Sensor Packaging: Dedicated tiered mounting plates and standoffs were modelled in 3D CAD to accommodate motor drivers, central computing nodes, power distribution PCBs and omni-directional vision mirror supports without wire-pinching or thermal congestion.
Manufacture-Ready Design
To support manufacturing and workshop fabrication across CNC milling, turning, sheet-metal laser cutting and 3D printing, Cadrill delivered an extensive drawing and CAD dataset:
- 2D production drawings for all CNC-milled gearbox housings and aluminium chassis plates with tight bearing bore tolerances.
- Flat-pattern sheet-metal drawings for internal component brackets, shielding and protective shell cowlings.
- Shaft, spline and gear fabrication details with keyway specifications and material heat-treatment guidelines.
- Full exploded assembly drawings with comprehensive fastener schedules and wiring conduit routing paths.
Project Outcome & Competition Honours
The completed mechanical design gave Qazvin Azad University's robotics team a robust, highly competitive autonomous platform. With Cadrill's mechanical architecture at its core, the team achieved outstanding international tournament results, earning 1st place at the RoboCup competition in Bangkok and 3rd place in the RoboCup competition in China.
Related Mechanical Design Services in Liverpool
If your organisation requires autonomous robotics design, mechatronic packaging, precision CNC machining, custom gearbox CAD or precision chassis engineering in Liverpool, Cadrill provides full-lifecycle engineering support. From mechanism kinematics and 3D SolidWorks modelling to CNC manufacturing drawings and prototype development, we collaborate with university research labs, tech startups and automation specialists throughout Liverpool, Merseyside and the UK.